|
Snehal Jauhri
I'm a Post-Doctoral researcher at the 3D AI Lab at the Technical University of Munich, working with
Angela Dai.
My research focuses on 3D visual scene understanding and generation, reinforcement learning, and embodied AI. |
|
Research InterestsComputer Vision, Reinforcement Learning, Vision-Language Models, Neural Fields, 3D Perception, Egocentric Perception, Embodied AI, Vision-Language-Action Models, Robot Learning |
News |
| Oct 2026 | Wrote a blog post here on how "Sim2Real for Robot Manipulation Is Finally Scaling" 🤖 |
| Oct 2026 | MolmoB0T was accepted as an Oral (top 3% of papers) at the Conference on Robot Learning (CoRL) 2026! See you in Austin, USA! 🤠 |
| Jun 2026 | MolmoB0T won Best Paper Awards 🏆 at the ICRA 2026 Workshops on VLA Pipelines and Synthetic Data for Robot Learning! |
| May 2026 | Started a Post-Doc at the 3D AI Lab at TU Munich, working with Prof. Angela Dai! |
| May 2026 | I defended my PhD at PEARL Lab, TU Darmstadt, Summa cum laude (mit Auszeichnung)! |
| May 2026 | MolmoSpaces was accepted at RSS 2026! See you in Sydney! 🇦🇺 |
| Apr 2026 | New preprint: WHOLE-MoMa: Whole-Body Mobile Manipulation using Offline Reinforcement Learning on Sub-optimal Controllers. |
| Mar 2026 | New preprint: MolmoB0T: Large-Scale Simulation Enables Zero-Shot Manipulation. |
| Jan 2026 | UniFField was accepted at ICRA 2026! See you in Vienna! 🇦🇹 |
| Sep 2025 | 2HandedAfforder was a Best Paper Award (Finalist) 🏆 at the Human to Robot (H2R) Workshop at the Conference on Robot Learning (CoRL) 2025! |
| Jul 2025 | 2HandedAfforder & 6DOPE-GS accepted at ICCV 2025! See you in Hawaii! 🌴 |
| Jun 2025 | Organizing the EgoAct Workshop on Egocentric Perception & Action for Robot Learning at RSS 2025. |
| May 2025 | Started as a Research Scientist Intern (PhD) at the Allen Institute for AI (Ai2) with the PRIOR team (CV & Embodied AI) in Seattle! 🇺🇸 |
| May 2024 | NeuGraspNet accepted at RSS 2024! See you in Delft! 🇳🇱 |
| May 2024 | Organizing the 2nd Workshop on Mobile Manipulation & Embodied Intelligence at ICRA 2024. |
| Feb 2024 | ActPerMoMa accepted at ICRA 2024! See you in Yokohama! 🇯🇵 |
| Jun 2023 | Presenting NeuGraspNet as a spotlight at the CVPR Workshop on 3D Vision & Robotics. |
| May 2023 | Organizing the Workshop on Representations, Abstractions, and Priors for Robot Learning (RAP4Robots) at ICRA 2023 in London! 🇬🇧 |
| Oct 2022 | Presented & won a Best Mobile Manipulation Paper Award 🏆 for “Robot Learning of Mobile Manipulation with Reachability Behavior Priors” at IROS 2022! |
| Jun 2022 | “Robot Learning of Mobile Manipulation with Reachability Behavior Priors” accepted at IEEE RA-L & IROS 2022! See you in Kyoto! ⛩️ |
Publications |
|
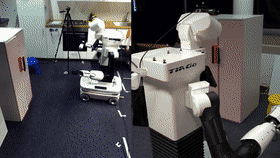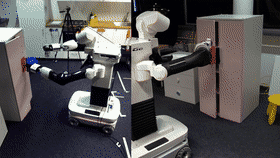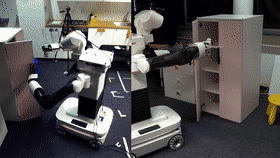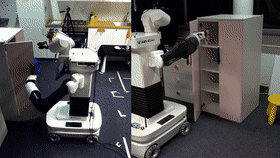
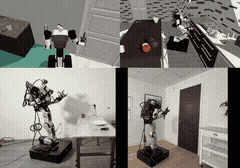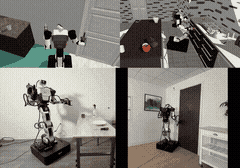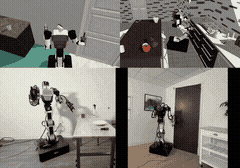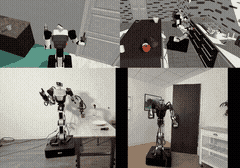
WHOLE-MoMa: Whole-Body Mobile Manipulation using Offline Reinforcement Learning on Sub-optimal Controllers
Snehal Jauhri, Vignesh Prasad, Georgia Chalvatzaki arXiv preprint, 2026 project page / arXiv |
|
MolmoB0T: Large-Scale Simulation Enables Zero-Shot Manipulation
Snehal Jauhri*, Abhay Deshpande*, Maya Guru*, Rose Hendrix*, Ainaz Eftekhar, Rohun Tripathi, Max Argus, Jordi Salvador, Haoquan Fang, Matthew Wallingford, Wilbert Pumacay, Yejin Kim, Quinn Pfeifer, Ying-Chun Lee, Piper Wolters, Omar Rayyan, Mingtong Zhang, Jiafei Duan, Karen Farley, Winson Han, Eli Vanderbilt, Dieter Fox, Ali Farhadi, Georgia Chalvatzaki, Dhruv Shah, Ranjay Krishna Conference on Robot Learning (CoRL), 2026 (Oral, top 3% of papers) Also presented at the ICRA 2026 Workshops on VLA Pipelines and Synthetic Data for Robot Learning (Best Paper Awards). project page / arXiv / code |
|
MolmoSpaces: Large-Scale Open Ecosystem for Robot Manipulation and Navigation
Yejin Kim, Wilbert Pumacay, Omar Rayyan, Max Argus, Winson Han, Eli VanderBilt, Jordi Salvador, Abhay Deshpande, Rose Hendrix, Snehal Jauhri, Shuo Liu, Nur Muhammad Mahi Shafiullah, Maya Guru, Arjun Guru, Ainaz Eftekhar, Karen Farley, Donovan Clay, Jiafei Duan, Piper Wolters, Alvaro Herrasti, Ying-Chun Lee, Georgia Chalvatzaki, Yuchen Cui, Ali Farhadi, Dieter Fox, Ranjay Krishna Robotics: Science and Systems (RSS), 2026 project page / arXiv / code |
|
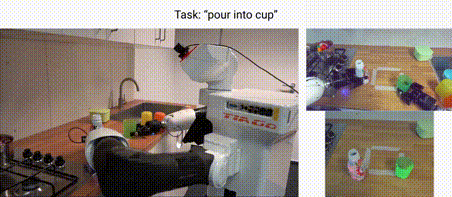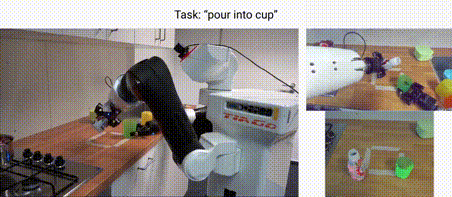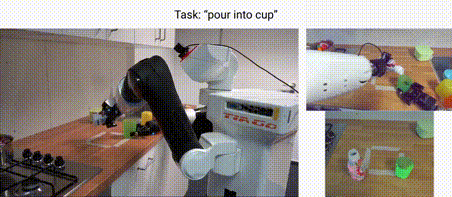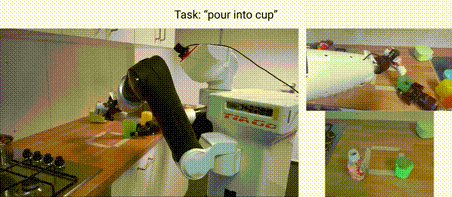
UniFField: A Generalizable Unified Neural Feature Field for Visual, Semantic, and Spatial Uncertainties in Any Scene
Snehal Jauhri*, Christian Maurer*, Sophie Lueth, Georgia Chalvatzaki IEEE International Conference on Robotics and Automation (ICRA), 2026. Also presented at the ICCV 2025 Open-World 3D Scene Understanding Workshop. project page / arXiv |
|
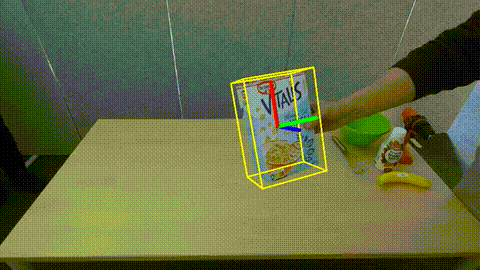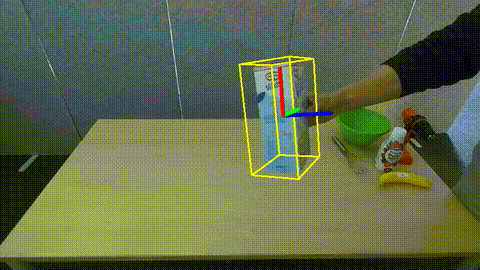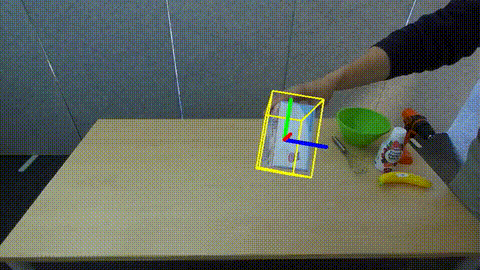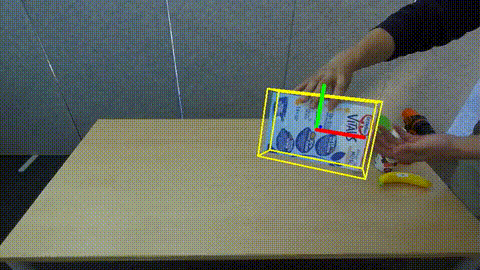
2HandedAfforder: Learning Precise Actionable Bimanual Affordances from Human Videos
Snehal Jauhri*, Marvin Heidinger*, Vignesh Prasad, Georgia Chalvatzaki IEEE/CVF International Conference on Computer Vision (ICCV), 2025. Also presented at the RSS 2025 EgoAct Workshop and the Conference on Robot Learning (CoRL) 2025 Human to Robot Workshop (Best Paper Award Finalist). project page / arXiv / code |
|
6DOPE-GS: Online 6D Object Pose Estimation using Gaussian Splatting
Yufeng Jin, Vignesh Prasad, Snehal Jauhri, Mathias Franzius, Georgia Chalvatzaki IEEE/CVF International Conference on Computer Vision (ICCV), 2025. Also presented at the RSS 2025 Gaussian Representations Workshop. project page / arXiv |
|
NeuGraspNet: Learning Any-View 6DoF Robotic Grasping in Cluttered Scenes via Neural Surface Rendering
Snehal Jauhri, Ishikaa Lunawat, Georgia Chalvatzaki Robotics: Science and Systems (RSS), 2024. Also presented as a spotlight at the CVPR 2023 Workshop on 3D Vision & Robotics. project page / arXiv / code |
|
ActPerMoMa: Active-Perceptive Motion Generation for Mobile Manipulation
Snehal Jauhri*, Sophie Lueth*, Georgia Chalvatzaki IEEE International Conference on Robotics and Automation (ICRA), 2024. project page / arXiv / code |
|
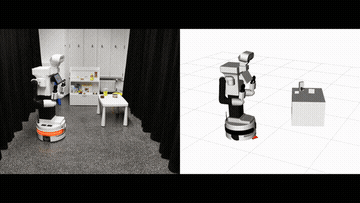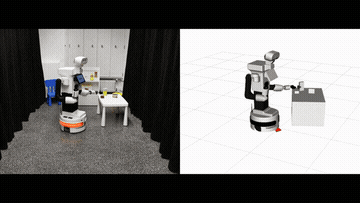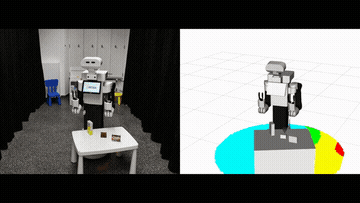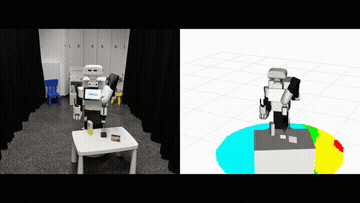
Robot Learning of Mobile Manipulation with Reachability Behavior Priors
Snehal Jauhri, Jan Peters, Georgia Chalvatzaki IEEE Robotics and Automation Letters (RA-L), vol. 7, no. 3, pp. 8399–8406, 2022. Presented at IROS 2022 (Best Mobile Manipulation Paper Award). project page / arXiv / code |
|
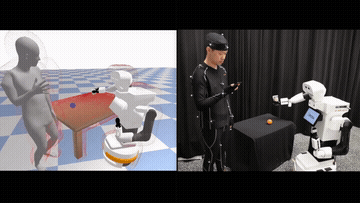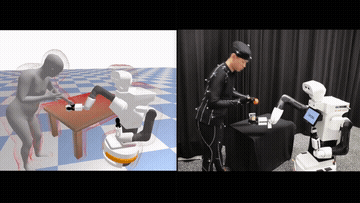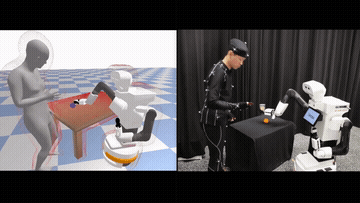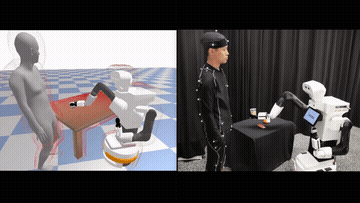
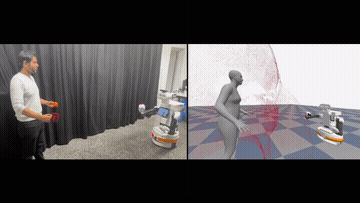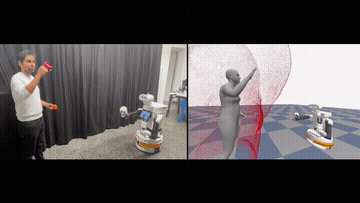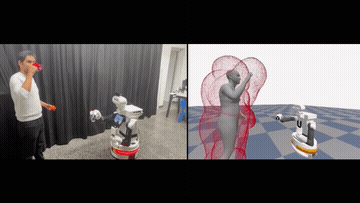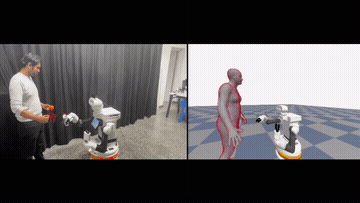
Safe Reinforcement Learning of Dynamic High-Dimensional Robotic Tasks: Navigation, Manipulation, Interaction
Puze Liu, Kuo Zhang, Davide Tateo, Snehal Jauhri, Zhiyuan Hu, Jan Peters, Georgia Chalvatzaki IEEE International Conference on Robotics and Automation (ICRA), 2023. project page / arXiv / code |
|
Regularized Deep Signed Distance Fields for Reactive Motion Generation
Puze Liu, Kuo Zhang, Davide Tateo, Snehal Jauhri, Jan Peters, Georgia Chalvatzaki IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022. project page / arXiv / code |
|
Interactive Imitation Learning in State-Space
Snehal Jauhri, Carlos Celemin, Jens Kober Conference on Robot Learning (CoRL), vol. 155, pp. 682–692, PMLR, 2020. arXiv / code |
|
Template credits: Jon Barron. Spouse credits: Brinda Mohan. |